 Crab Bot
Robots · 2,304 tris
Walks · 6 legs
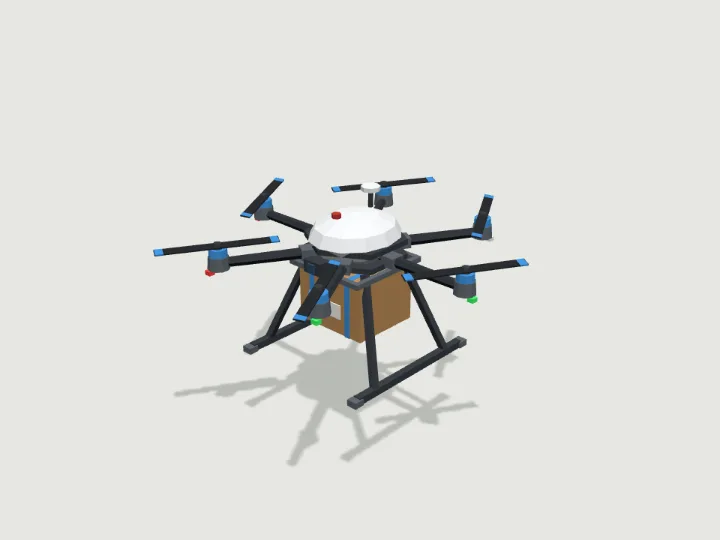
drag to orbit · tap the ground to send it
Mech · Flies
Cargo Drone
A heavy-lift delivery multirotor, 1.6 m across the props, with six (or eight) rotors on folding arms, tall landing gear and a parcel, crate or insulated cooler clamped in a cradle under the belly. Flies by distance: the rotors spin in counter-rotating pairs and the airframe bobs; navigation lights and a belly beacon glow at night.
- Size
- 1.8 × 0.79 × 1.2 m
- Triangles
- 1,780
- Kit
- Robots
Tune it
4 knobs: Scheme, Rotors, Payload, Size.
Specs
- Size
- 1.8 × 0.79 × 1.2 m width × height × depth
- Triangles
- 1,780 of 6,000
- Draw calls
- 1 one vertex-colour material
- Loop clip
- 0.6 m of travel per cycle
- Altitude
- 3 m above the ground
- Moving parts
- 7 rotor_0 · spin, rotor_1 · spin, rotor_2 · spin, rotor_3 · spin, rotor_4 · spin, rotor_5 · spin, frame · slide
- Knobs
- 4 3 presets
- Night lights
- 2 led, beacon
Passed the validator: real scale, rests on y = 0, front faces +Z, deterministic.
Use it
Code for the specimen as it is set up above; it follows your knobs.
import { createAsset } from 'https://gaitkit.com/cdn/cargo-drone.mjs';

const cargoDrone = createAsset();
scene.add(cargoDrone);                      // rests on y = 0, front faces +Z

let dist = 0;
renderer.setAnimationLoop(() => {
  dist += speed * clock.getDelta();
  cargoDrone.position.set(0, groundY + cargoDrone.userData.altitude, dist);
  cargoDrone.userData.tick(dist);            // wings beat with the distance
  renderer.render(scene, camera);
});import { useMemo, useRef } from 'react';
import { useFrame } from '@react-three/fiber';
import { createAsset } from 'https://gaitkit.com/cdn/cargo-drone.mjs';
export function CargoDrone({ speed = 1 }) {
const model = useMemo(() => createAsset(), []);
const dist = useRef(0);
useFrame((_, dt) => {
dist.current += speed * dt;
model.position.set(0, groundY + model.userData.altitude, dist.current);
model.userData.tick(dist.current); // wings beat with the distance
});
return <primitive object={model} />;
}# Import cargo-drone.glb (download below). It carries an in-place "Loop" animation.
@onready var anim: AnimationPlayer = $CargoDrone/AnimationPlayer
func _physics_process(delta):
velocity = transform.basis.z * speed
move_and_slide()
anim.play("Loop")
anim.speed_scale = speed / 0.6 # one Loop = 0.6 m of travel// Import cargo-drone.glb with glTFast (com.unity.cloud.gltfast).
animator.Play("Loop");
animator.speed = speed / 0.6 // one Loop = 0.6 m of travelUse the gaitkit MCP server: get_variant({ "id": "cargo-drone", "want": "default look" })
then place the result.
# MCP endpoint
https://gaitkit.com/mcpKnobs
| Knob | Type | Values | Default | What it does |
|---|---|---|---|---|
scheme | choice | white graphite safety olive | white | Colour scheme: white (courier service, blue trim), graphite (dark grey, amber trim), safety (orange utility drone), olive (field and farm green). |
rotors | choice | 6 8 | 6 | Number of arms and propellers: 6 (hexacopter) or 8 (octocopter, smaller props, for heavier loads). |
payload | choice | parcel crate cooler none | parcel | What hangs in the cradle under the belly: a strapped cardboard parcel, a slatted wooden crate, a white insulated cooler with a handle (food or medicine), or nothing. |
size | range | 0.6 to 1.6, step 0.05 | 1 | Uniform scale. 1 is 1.6 m across the props and 0.75 m tall on its gear; 1.6 is a 2.5 m freight lifter. |
Presets: medicine run {"scheme":"white","payload":"cooler"} · farm lifter {"scheme":"olive","rotors":8,"payload":"crate","size":1.4} · night freight {"scheme":"graphite","rotors":8}
Files
| File | What |
|---|---|
| cargo-drone.glb | GLB, default look · 250 KB |
| cargo-drone.mjs | ES module, every knob live |
| cargo-drone.obj | OBJ, static, no colour |
| cargo-drone-params.json | knob schema, presets, night zones |
Licence
Use it in games, apps, renders and client work, commercially and without credit. Do not resell it as an asset or train a 3D generator on it. The full licence.
More from Robots
Crab Bot
Robots · 2,304 tris
Walks · 6 legs
 Delivery Robot
Robots · 904 tris
Rolls
 Robot Arm
Robots · 1,012 tris
Moving parts
 Security Drone
Robots · 1,752 tris
Flies
 Service Bot
Robots · 2,316 tris
Rolls
 Tank Bot
Robots · 1,956 tris
Rolls
 Vacuum Bot
Robots · 1,048 tris
Rolls
 Welding Bot
Robots · 1,772 tris
Moving parts