 Cargo Drone
Robots · 1,780 tris
Flies
drag to orbit
Mech · 8 moving parts
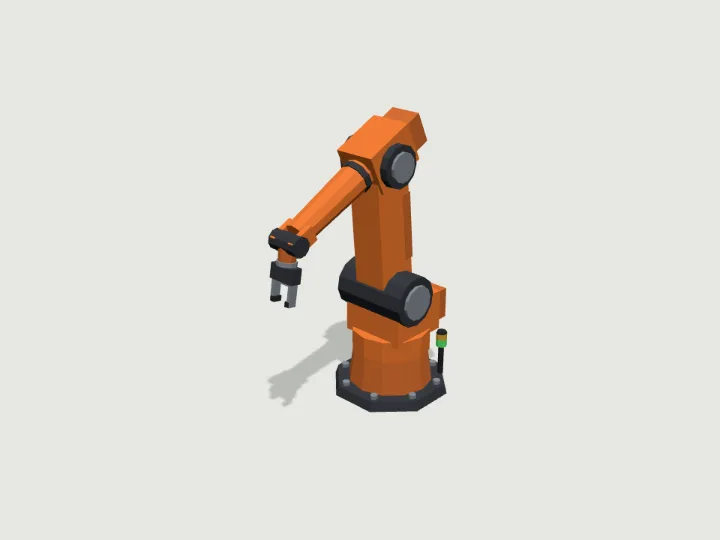
Robot Arm
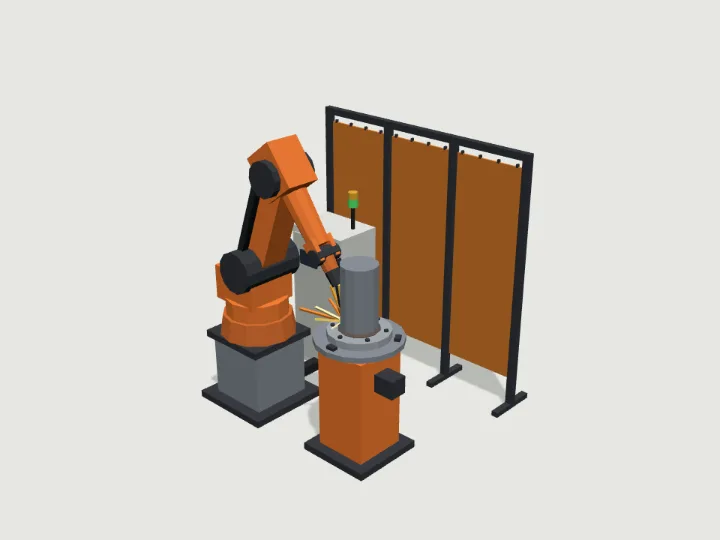
A floor-mounted six-axis industrial robot arm, about 1.8 m tall at rest, with a gripper, a welding torch or a suction head. Every joint (base yaw, shoulder, elbow, forearm roll, wrist pitch, flange roll) is a named rotate rig at its real axis, and userData.tick plays one full pick-and-place cycle per loop; a stack light on the base glows at night.
- Size
- 0.70 × 1.8 × 1.3 m
- Triangles
- 1,012
- Kit
- Robots
Tune it
4 knobs: Paint, Tool, Reach, Pedestal.
Specs
- Size
- 0.70 × 1.8 × 1.3 m width × height × depth
- Triangles
- 1,012 of 6,000
- Draw calls
- 1 one vertex-colour material
- Loop clip
- 6.283 m of travel per cycle
- Moving parts
- 8 joint_1 · rotate, joint_2 · rotate, joint_3 · rotate, joint_4 · rotate, joint_5 · rotate, joint_6 · rotate, finger_L · slide, finger_R · slide
- Knobs
- 4 3 presets
- Night lights
- 1 lamp
Passed the validator: real scale, rests on y = 0, front faces +Z, deterministic.
Use it
Code for the specimen as it is set up above; it follows your knobs.
import { createAsset } from 'https://gaitkit.com/cdn/robot-arm.mjs';

const robotArm = createAsset();
scene.add(robotArm);                      // rests on y = 0, front faces +Z

// 'joint_1' pivots on its hinge: -50° to 55° around y
robotArm.getObjectByName('joint_1').rotation.y = THREE.MathUtils.degToRad(-50);import { useMemo } from 'react';
import { createAsset } from 'https://gaitkit.com/cdn/robot-arm.mjs';
export function RobotArm() {
const model = useMemo(() => createAsset(), []);
return <primitive object={model} />;
}# Import robot-arm.glb (download below). Moving parts are separate nodes, pivoted on their hinge.
$RobotArm/joint_1.rotation_degrees.y = -50// Import robot-arm.glb with glTFast (com.unity.cloud.gltfast).
transform.Find("joint_1").localEulerAngles = new Vector3(/* y: */ -50, 0, 0);Use the gaitkit MCP server: get_variant({ "id": "robot-arm", "want": "default look" })
then place the result.
# MCP endpoint
https://gaitkit.com/mcpKnobs
| Knob | Type | Values | Default | What it does |
|---|---|---|---|---|
paint | choice | orange yellow blue white | orange | Arm colour: orange or yellow (classic factory robots), blue, or white (clean-room or collaborative robot look). |
tool | choice | gripper torch suction | gripper | End effector on the flange: gripper (two fingers that close on the part), torch (a bent welding torch with a copper nozzle) or suction (four vacuum cups on a plate, for boxes and sheets). |
reach | range | 0.7 to 1.4, step 0.05 | 1 | Length of the upper arm and forearm. 1 reaches about 1.6 m; 0.7 is a compact bench robot, 1.4 a long-reach palletiser. |
pedestal | toggle | on / off | false | Stands the robot on a 0.5 m steel riser with a ladder of bolts, as in welding and packing cells. |
Presets: packing cell {"tool":"suction","paint":"yellow","reach":1.3,"pedestal":true} · welding robot {"tool":"torch","paint":"blue"} · clean room {"paint":"white","reach":0.8}
Files
| File | What |
|---|---|
| robot-arm.glb | GLB, default look · 137 KB |
| robot-arm.mjs | ES module, every knob live |
| robot-arm.obj | OBJ, static, no colour |
| robot-arm-params.json | knob schema, presets, night zones |
Licence
Use it in games, apps, renders and client work, commercially and without credit. Do not resell it as an asset or train a 3D generator on it. The full licence.
More from Robots
Cargo Drone
Robots · 1,780 tris
Flies
 Crab Bot
Robots · 2,304 tris
Walks · 6 legs
 Delivery Robot
Robots · 904 tris
Rolls
 Security Drone
Robots · 1,752 tris
Flies
 Service Bot
Robots · 2,316 tris
Rolls
 Tank Bot
Robots · 1,956 tris
Rolls
 Vacuum Bot
Robots · 1,048 tris
Rolls
 Welding Bot
Robots · 1,772 tris
Moving parts