 Battle Mech
Mech Hangar · 1,664 tris
Walks · 2 legs
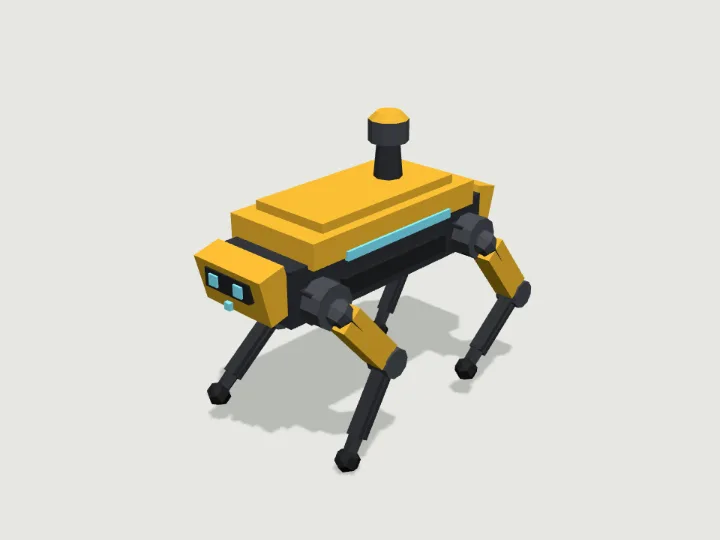
drag to orbit · tap the ground to send it
Mech · Walks on 4 legs
Robo Dog
A knee-high four-legged inspection robot, about 0.9 m long. Trots on diagonal pairs or walks one foot at a time; the knees can bend back, inward or outward like real legged robots, and an optional lidar or arm rides on its back.
- Size
- 0.49 × 0.84 × 0.96 m
- Triangles
- 1,384
- Kit
- Mech Hangar
Tune it
5 knobs: Colorway, Knees, Gait, Payload, Size.
Specs
- Size
- 0.49 × 0.84 × 0.96 m width × height × depth
- Triangles
- 1,384 of 6,000
- Draw calls
- 1 one vertex-colour material
- Legs
- 4 2 gait groups
- Stride
- 26 cm duty factor 0.56
- Foot slide
- 0.00 mm limit 1 mm
- Walk clip
- 0.65 m/s at playback speed 1
- Moving parts
- 1 lidar · spin
- Knobs
- 5 3 presets
- Night lights
- 2 eye, lamp
Passed the validator: real scale, rests on y = 0, front faces +Z, deterministic, planted feet never slide past 1 mm.
Use it
Code for the specimen as it is set up above; it follows your knobs.
import { createAsset } from 'https://gaitkit.com/cdn/robo-dog.mjs';
import { walker } from 'https://gaitkit.com/runtime/walk.mjs';

const roboDog = createAsset();
scene.add(roboDog);                      // rests on y = 0, front faces +Z
const gait = walker(roboDog, { ground: (x, z) => terrainHeight(x, z) });   // or omit ground for a flat floor

let dist = 0;
renderer.setAnimationLoop(() => {
  dist += speed * clock.getDelta();
  roboDog.position.z = dist;
  gait.poseAt(dist);                  // feet stay planted, at any frame rate
  renderer.render(scene, camera);
});import { useMemo, useRef } from 'react';
import { useFrame } from '@react-three/fiber';
import { createAsset } from 'https://gaitkit.com/cdn/robo-dog.mjs';
import { walker } from 'https://gaitkit.com/runtime/walk.mjs';
export function RoboDog({ speed = 1 }) {
const model = useMemo(() => createAsset(), []);
const gait = useMemo(() => walker(model), [model]);
const dist = useRef(0);
useFrame((_, dt) => {
dist.current += speed * dt;
model.position.z = dist.current;
gait.poseAt(dist.current); // feet stay planted, at any frame rate
});
return <primitive object={model} />;
}# Import robo-dog.glb (download below). It carries an in-place "Walk" animation.
@onready var anim: AnimationPlayer = $RoboDog/AnimationPlayer
func _physics_process(delta):
velocity = transform.basis.z * speed
move_and_slide()
anim.play("Walk")
anim.speed_scale = speed / 0.65 # Walk clip covers 0.65 m/s at 1x// Import robo-dog.glb with glTFast (com.unity.cloud.gltfast).
animator.Play("Walk");
animator.speed = speed / 0.65 // Walk clip covers 0.65 m/s at 1xUse the gaitkit MCP server: get_variant({ "id": "robo-dog", "want": "default look" })
then place the result and walk it with walker() so the feet stay planted.
# MCP endpoint
https://gaitkit.com/mcpKnobs
| Knob | Type | Values | Default | What it does |
|---|---|---|---|---|
colorway | choice | safety arctic stealth rescue | safety | Shell and frame colours: safety (yellow/black), arctic (white/grey, red trim), stealth (black, teal lights), rescue (orange/white). |
knees | choice | back inward outward | back | Which way the knees bend: back (all four point backward), inward (front back, hind forward: knees point to the middle), outward (front forward, hind back, like an animal). |
gait | choice | trot walk | trot | trot: diagonal leg pairs move together (fast, two feet down). walk: one foot at a time, three feet always down (careful, for rough ground). |
payload | choice | none lidar arm | lidar | What rides on the back: none, a spinning lidar mast, or a folded manipulator arm with a gripper. |
size | range | 0.6 to 1.8, step 0.05 | 1 | Uniform scale. 1 is about 0.9 m long and 0.6 m tall; 1.8 is a pony-sized cargo walker. |
Presets: patrol unit {"colorway":"stealth","payload":"lidar"} · rescue walker {"colorway":"rescue","payload":"arm","gait":"walk","size":1.3} · lab unit {"colorway":"arctic","knees":"inward","payload":"none"}
Files
| File | What |
|---|---|
| robo-dog.glb | GLB, default look · 197 KB |
| robo-dog.mjs | ES module, every knob live |
| robo-dog.obj | OBJ, static, no colour |
| robo-dog-params.json | knob schema, presets, night zones |
Licence
Use it in games, apps, renders and client work, commercially and without credit. Do not resell it as an asset or train a 3D generator on it. The full licence.
More from Mech Hangar
Battle Mech
Mech Hangar · 1,664 tris
Walks · 2 legs
 Exosuit
Mech Hangar · 1,928 tris
Walks · 2 legs
 Hexapod Tank
Mech Hangar · 2,540 tris
Walks · 6 legs
 Loader Mech
Mech Hangar · 1,872 tris
Walks · 2 legs
 Mech Hangar Bay
Mech Hangar · 2,012 tris
Moving parts
 Scout Mech
Mech Hangar · 1,096 tris
Walks · 2 legs
 Sentry Turret
Mech Hangar · 600 tris
Moving parts
 Siege Walker
Mech Hangar · 2,832 tris
Walks · 4 legs